A blind Unitree G1 humanoid flips a skateboard in what its builders call the first robot kickflip
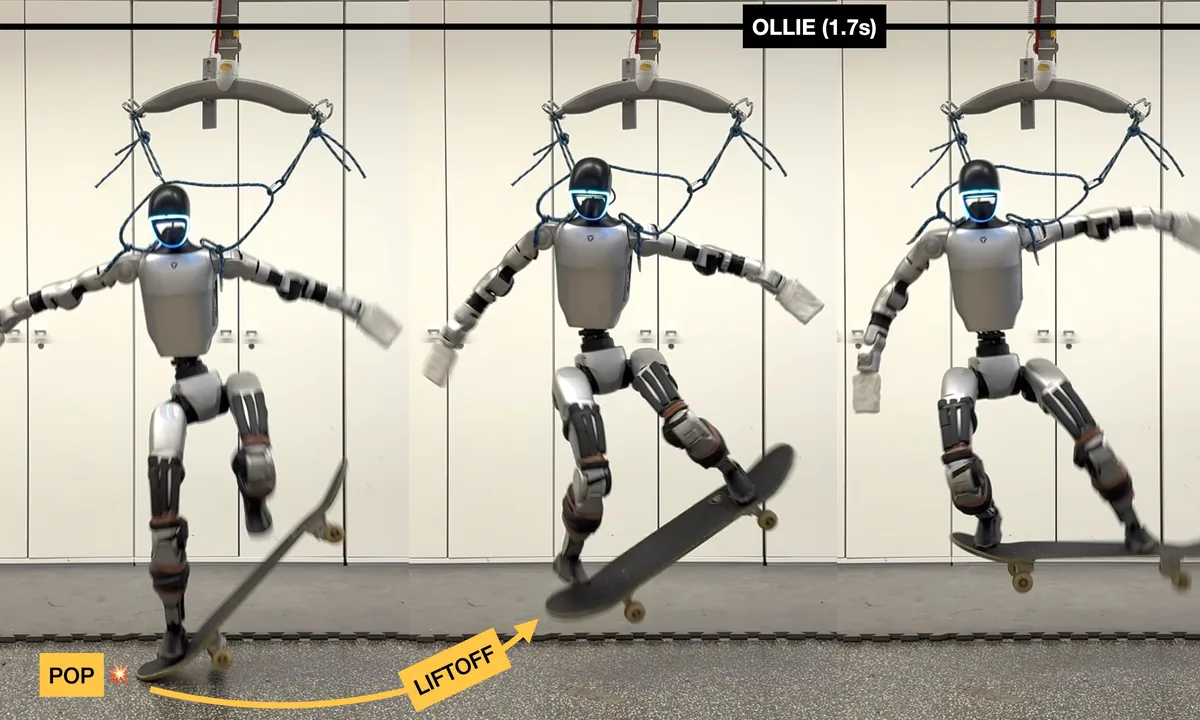
Researchers at Germany's DFKI and TU Darmstadt say they taught a Unitree G1 humanoid skateboard tricks, a first for any humanoid, they believe. On Oct. 31, PhD student Aditya Bhatt posted a clip he called "the world's first robot kickflip." In it, the board flips and the robot lands on it, then loses its balance and drops into an overhead safety harness. An on-screen label reads "working on it."
Their workshop paper lists eight skills, including mounting, pushing, ollies, pop shove-its and kickflips, all run on the real robot. The skills are "blind": the robot uses only its joint encoders and motion sensor, with no camera, board tracking, markers, or touch or force sensors. It finds its footing by feeling the board through contact, they say.
The paper is a preliminary report: success rates of 73% to 91% for four skills come from simulation, and hardware results are qualitative. Bhatt says the full paper and code are coming "any day now."
Why it matters
Most robots that handle objects lean on cameras or touch sensors. The researchers argue a standard humanoid can get a rough sense of touch from its own joint readings, which could make today's robots more capable without new hardware. A clean, repeatable kickflip on real hardware still needs the full paper and hardware numbers.
About the footage: Real robot, per the paper, using only its onboard joint encoders and IMU. The clip shows the robot in a rope safety harness hung from an overhead hoist, which catches it when it falls after the kickflip; on-screen labels mark the trick at 1x and at 0.125x (slow motion).
The source post
Post by Aditya Bhatt (DFKI / TU Darmstadt researcher) on X.
View the post on X
Sources
- @aditya_bhatt on X (Aditya Bhatt, PhD student at DFKI / TU Darmstadt and the paper's first author)
- TU Darmstadt Intelligent Autonomous Systems lab: The Blind Skateboarder (robot videos page)
- Bhatt et al., The Blind Skateboarder: Unlocking Dexterous Robotic Skateboarding via Interactive Perception (IROS 2026 workshop paper, PDF)
- IROS 2026 Haptics Workshop: Blind Whole-Body Haptic Dexterity Without Tactile Sensors (accepted poster)
New to robots? Start with our beginner's guide to how robots work.
Summarized by Servospace from the sources above, drafted with AI help and checked against those sources before publishing. Claims are the companies' or outlets' unless we say otherwise. How we work.